Autonomous Landing
A three-tier vision pipeline that brings a drone down without GPS.
Detection, a QR fallback, and EPnP pose estimation — designed for the edge, where a missed frame is a crash.
Portfolio & field notes — 2026
机器如何看。
I build vision systems for drones and phones — and write about the distance between what a model sees and what we meant.
01 Selected work
Four systems, one question: what does the model actually see?
All work
A three-tier vision pipeline that brings a drone down without GPS.
Detection, a QR fallback, and EPnP pose estimation — designed for the edge, where a missed frame is a crash.
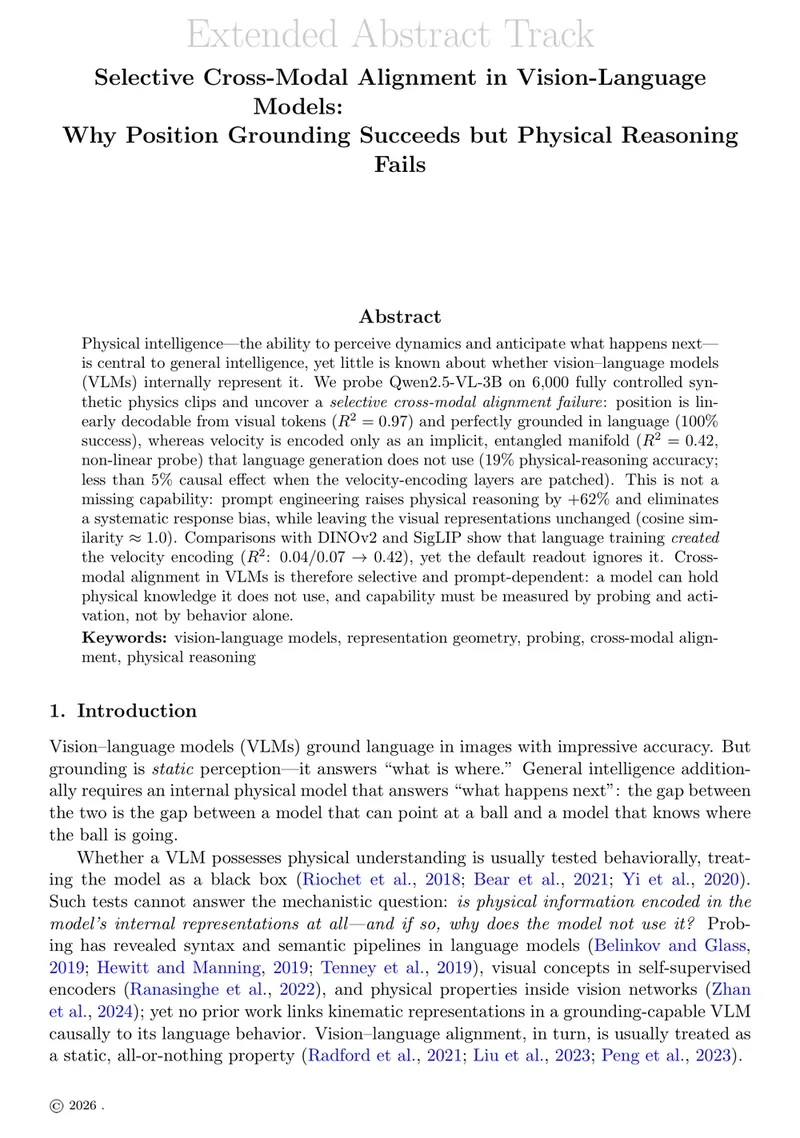
What Qwen2.5-VL can decode, and what it refuses to reason about.
A controlled study of 6,000 physical videos: position is linearly decodable, velocity is entangled, and prompting recovers part of the gap.
An AI coding agent that lives on an Android phone.
Kotlin and Compose, a streaming agent loop, a Python sandbox, and twenty hardware controls. One device, no laptop.
Link prediction when more than half the graph has never been seen.
A zero-parameter heat feature and a local MRR benchmark took the team from 0.9357 to 1.2443.
On error
A model does not fail loudly. It fails in the space between the label and the thing itself.From “The 18.4% Problem” ↗
Research / NeurIPS 2026
Why position grounding succeeds but physical reasoning fails.
6,000 controlled physics clips. Position is explicit; velocity is a manifold the language head ignores.